
IIR Bessel - II Order
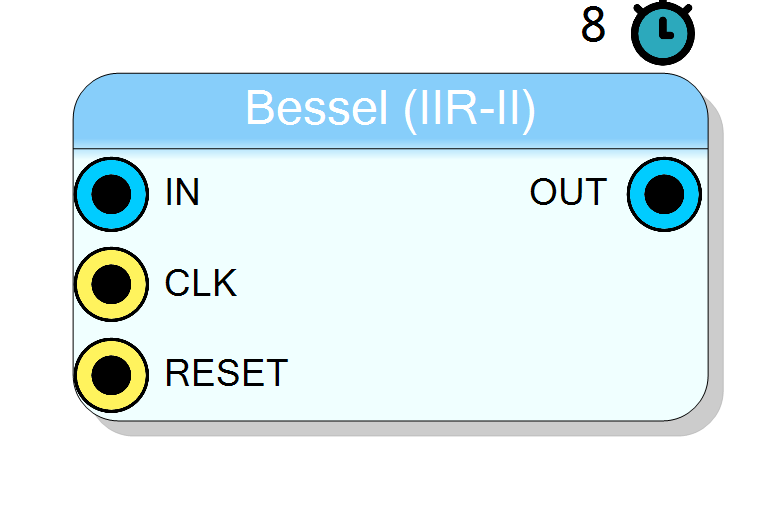
Second-order Bessel IIR filter with maximally flat group delay. Preserves wave shape of filtered signals in the passband with minimal overshoot.
Introduction
The IIR Bessel - II Order block implements a second-order IIR (Infinite Impulse Response) filter operating in real time on FPGA. The component includes automatic filter coefficient calculation based on filter type (low/high pass) and cutoff frequency.
The Bessel filter is named after German mathematician Friedrich Bessel (1784-1846), who developed the mathematical theory on which the filter is based. It is also called Bessel-Thomson filter in recognition of W. E. Thomson, who applied Bessel functions to filter design in 1949.
Pin Description
Properties
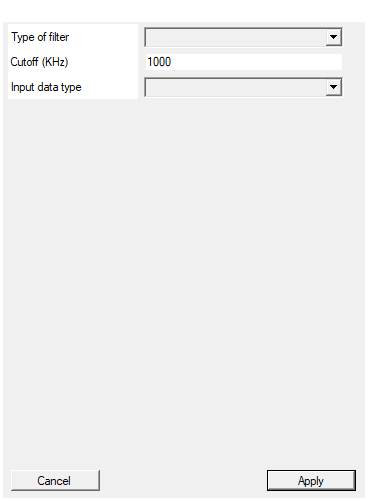
Select between low pass and high pass filter
Filter type selection. Available values: Low Pass, High Pass, default Low Pass.Default: Low Pass
Options: Low Pass High Pass
Set the filter pole/zero position according to the selected bandwidth in KHz
Cutoff frequency in kHz. Must be less than half the sampling frequency (Nyquist limit).Default: 1000
Select input data type
Input data format selection. Available values: Unsigned 16 bit, Signed 17 bit, default Unsigned 16 bit.Default: UINT16
Options: UINT16 INT17
Usage
Bessel Filter Characteristics
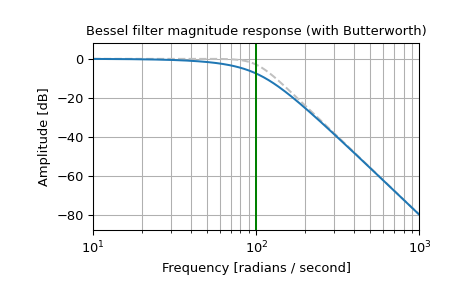
The Bessel filter has a maximally flat group delay (maximally linear phase response), which preserves the wave shape of filtered signals in the passband. Key characteristics include:
- Linear Phase Response: Minimizes signal distortion in time domain
- Low Overshoot: Much less overshoot than Butterworth or Chebyshev filters
- Gaussian-like Response: Impulse response tends towards Gaussian as filter order increases
- Smooth Transition: Gentle roll-off between passband and stopband
Digital Implementation Note
The Bessel filter is inherently an analog filter. This implementation generates digital Bessel filters using the bilinear transform, which does not perfectly preserve the phase response of the analog filter. The phase response is only approximately correct at frequencies below about fs/4.
Scattered Lookahead Implementation
To enable real-time FPGA operation at full clock rate, the filter uses the Scattered Lookahead technique. This transforms the recursive IIR structure to allow pipelined parallel processing:
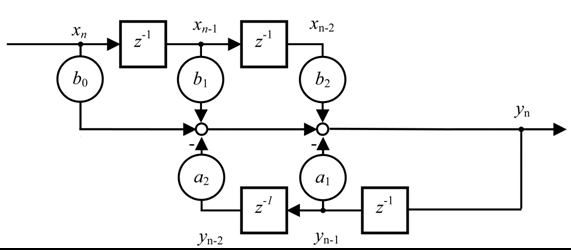
The standard IIR equation:
$$ y[n] = b_0 x[n] + b_1 x[n-1] + b_2 x[n-2] - a_1 y[n-1] - a_2 y[n-2] $$
Is transformed using scattered lookahead to:
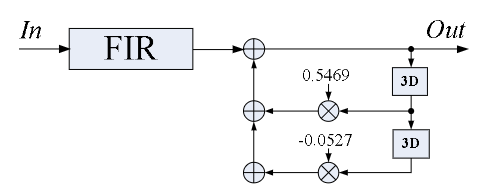
$$ y[j] = \sum_{k=0}^{6} b’_k x[j-k] - a’_3 y[j-3] - a’_6 y[j-6] $$
Reference: A universal look-ahead algorithm for pipelining IIR filters
Coefficient Calculation
SciCompiler automatically calculates the filter coefficients using the internal filter calculator tool. The following Python code provides a reference implementation for offline simulation:
python
import numpy as np
from scipy import signal
def scattered_lookahead_transform(a):
A = np.array([[a[0], 0, 0, 0, 0, ],
[a[1], a[0], 0, 0, 0, ],
[a[2], a[1], a[0], 0, 0, ],
[0, 0, a[2], a[1], a[0], ],
[0, 0, 0, a[2], a[1], ]])
A_inv = np.linalg.inv(A)
D = A_inv * [1, 0, 0, 0, 0]
D1 = D[:,0]
D = D[:,0].reshape(-1, 1)
R = np.array([[ 0, a[2], a[1], a[0], 0, ],
[0, 0, 0, 0, a[2]]])
Qw = np.dot(R, D)
an = [1, Qw[0][0], Qw[1][0]]
bn = D1
return bn, an
N = 2 # Order of the filter
fs = 250*1e6 # Sampling frequency
fc = 5*1e6 # Corner frequency
Wn = fc/(fs/2)
b_z, a_z = signal.bessel(N, Wn, btype='low')
print("original", b_z, a_z)
bn, an = scattered_lookahead_transform(a_z)
bq = np.convolve(bn, b_z)
aq = an
print("scattered", bq, aq)
Typical Applications
- Signal conditioning with minimal pulse distortion
- Anti-aliasing filters requiring low overshoot
- Audio and measurement systems requiring linear phase
- Nuclear pulse processing where pulse shape preservation is critical
Resources & Timing
- Latency: 8 clock cycles